Drone
This element is a basic drone. The graphic origin of the Drone corresponds to the geometric center of the Drone.
| Is an equipment | ❌ |
| Can have equipment | ✔️ |
This element must be used with 2D scene context.
Icon

2D Representation
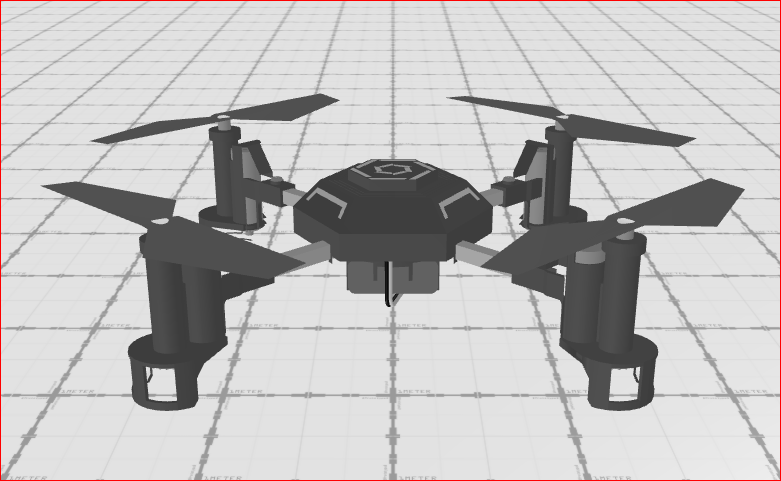
3D Representation
External parameters
You can edit the units
Show/Hide all parameters
| parameter | editable via "Parameter" tab | updatable via a controller | description | default unit | type |
|---|---|---|---|---|---|
| Trajectory | ✔️ | ❌ | Trajectory of the scene that the drone will follow. | - | Enumeration |
| Curvilinear position | ✔️ | ✔️ | Position on the trajectory. | meter | Decimal number |
| X-axis position | ✔️ | ✔️ | Position of the element on the X-axis. | meter | Decimal number |
| Y-axis position | ✔️ | ✔️ | Position of the element on the Y-axis. | meter | Decimal number |
| Z-axis position | ❌ | ❌ | Position of the element on the Z-axis. | meter | Decimal number |
| X-axis speed | ✔️ | ✔️ | Speed on the X-axis of the drone. This parameter can be profile. | kilometers per hour | Decimal number |
| Y-axis speed | ✔️ | ✔️ | Speed on the Y-axis of the drone. This parameter can be profile. | kilometers per hour | Decimal number |
| Z-axis speed | ✔️ | ✔️ | Speed on the Z-axis of the drone. This parameter can be profile. | kilometers per hour | Decimal number |
| X-axis acceleration | ✔️ | ✔️ | Acceration on the X-axis of the drone. | kilometers per hour squared | Decimal number |
| Y-axis acceleration | ✔️ | ✔️ | Acceration on the Y-axis of the drone. | kilometers per hour squared | Decimal number |
| Z-axis acceleration | ✔️ | ✔️ | Acceration on the Z-axis of the drone. | kilometers per hour squared | Decimal number |
| X-axis angle | ❌ | ❌ | Angle of the element on the X-axis. | degree | Decimal number |
| Y-axis angle | ❌ | ❌ | Angle of the element on the Y-axis. | degree | Decimal number |
| Z-axis angle | ✔️ | ✔️ | Angle of rotation of the element compared to its initial position. | degree | Decimal number |
| X-axis rotation speed | ✔️ | ✔️ | Rotation speed on the X-axis of the drone. | radian per second | Decimal number |
| Y-axis rotation speed | ✔️ | ✔️ | Rotation speed on the Y-axis of the drone. | radian per second | Decimal number |
| Z-axis rotation speed | ✔️ | ✔️ | Rotation speed on the Z-axis of the drone. | radian per second | Decimal number |
| X-axis rotation acceleration | ✔️ | ✔️ | Rotation acceleration on the X-axis of the drone. | radian per second squared | Decimal number |
| Y-axis rotation acceleration | ✔️ | ✔️ | Rotation acceleration on the Y-axis of the drone. | radian per second squared | Decimal number |
| Z-axis rotation acceleration | ✔️ | ✔️ | Rotation acceleration on the Z-axis of the drone. | radian per second squared | Decimal number |
| Visibility | ✔️ | ✔️ | This parameter allows you to choose if you want the element to be visible or not on the scene during the execution of the scenario. If the item is part of a group, it can inherit the value of that group. | - | Enumeration (visible, hidden, inherit) |
| Threshold zoom out | ✔️ | ❌ | Zoom level from which its representation on the scene is no longer modified. | % | Decimal number |
| Length | ❌ | ❌ | Length of the drone. | meter | Decimal number |
| Width | ❌ | ❌ | Width of the drone. | meter | Decimal number |
| Height | ❌ | ❌ | Height of the drone. | meter | Decimal number |
| Vehicle Profile | ❌ | ❌ | Profile of the drone. | - | Enumeration |
| longitude coordinate | ❌ | ❌ | Automatically calculated longitude value, based on the origin defined for the context and the position of the element. | degree | Decimal number |
| latitude coordinate | ❌ | ❌ | Automatically calculated latitude value, based on the origin defined for the context and the position of the element. | degree | Decimal number |
Triggered behaviours
See Actions page for more explanation.
Show/Hide all triggered behaviours
Destroy
At the reception of the flow, the element is destroy.
No parameters for this triggered behaviour.
Update Trajectory
| parameter | editable via "Parameter" tab | updatable via a controller | description | default unit | type |
|---|---|---|---|---|---|
| Reset Curvilinear Position | ❌ | ✔️ | Update position on the trajectory. | meter | Decimal number |
| Trajectory Name | ❌ | ✔️ | Name of the trajectory that the car will follow. | - | TextType |
Events
See Events page for more explanation.
Show/Hide all events
| event | description |
|---|---|
| On Parameter Value Changed | The element can send information to the model when the value of the selected parameter has changed |
| Continually | The drone can send information to the model continuously |
| At initialization | The drone can send information to the model once at initialization |